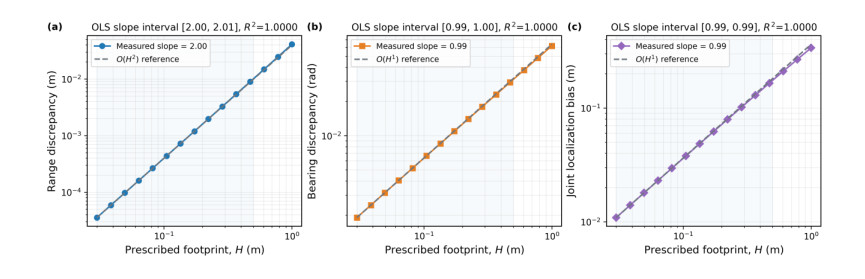
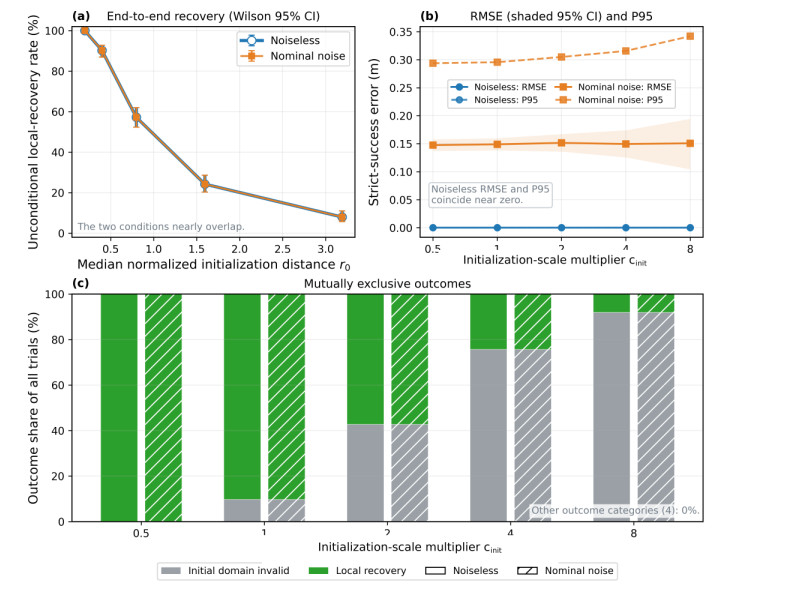
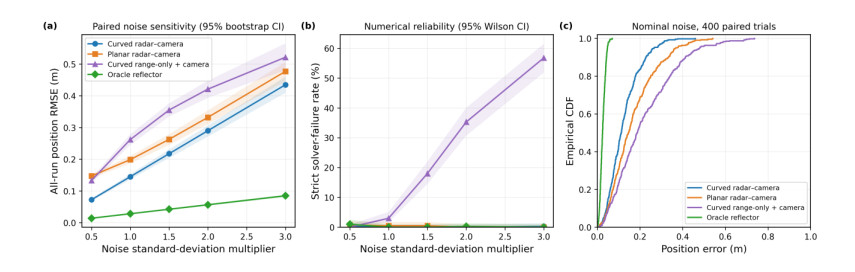
This paper develops a curvature-aware specular-reflection inverse-geometry model for camera-assisted millimeter-wave non-line-of-sight localization with an unknown curved reflector and a hidden target. In a calibrated two-dimensional setting, a finite-dimensional C3 regular curve, a locally selected nondegenerate Fermat branch, radar range/azimuth measurements, and camera-derived reflector constraints form a whitened augmented forward operator. Implicit differentiation yields a reduced Jacobian for analyses of local identifiability, Fisher-Schur information, and small-perturbation stability. The tangent-plane approximation induces a second-order range bias, but the azimuth and generic localization biases remain first order. A scaled Levenberg-Marquardt solver is evaluated using 400 paired synthetic trials. Under nominal noise, the curved fusion model attains a localization root-mean-square error (RMSE) of 0.145 m versus 0.199 m for the planar model; the paired 95% bootstrap improvement interval is [0.0444, 0.0625] m. Initialization-scale tests and a deterministic 12-geometry, two-level Plackett-Burman screen further characterize empirical local recovery and within-design geometric sensitivity. These synthetic results are limited to calibrated two-dimensional geometry, a finite-dimensional reflector, known single-bounce association, a nongrazing local branch, and branch-valid initialization; they do not establish global path uniqueness, convergence from arbitrary initial values, or vehicle-mounted experimental validity.
Citation: Shih-Lin Lin. Curvature-aware inverse specular geometry for camera-assisted mmWave NLoS localization: identifiability, stability, and numerical analysis[J]. AIMS Mathematics, 2026, 11(10): 34661-34698. doi: 10.3934/math.20261351
This paper develops a curvature-aware specular-reflection inverse-geometry model for camera-assisted millimeter-wave non-line-of-sight localization with an unknown curved reflector and a hidden target. In a calibrated two-dimensional setting, a finite-dimensional C3 regular curve, a locally selected nondegenerate Fermat branch, radar range/azimuth measurements, and camera-derived reflector constraints form a whitened augmented forward operator. Implicit differentiation yields a reduced Jacobian for analyses of local identifiability, Fisher-Schur information, and small-perturbation stability. The tangent-plane approximation induces a second-order range bias, but the azimuth and generic localization biases remain first order. A scaled Levenberg-Marquardt solver is evaluated using 400 paired synthetic trials. Under nominal noise, the curved fusion model attains a localization root-mean-square error (RMSE) of 0.145 m versus 0.199 m for the planar model; the paired 95% bootstrap improvement interval is [0.0444, 0.0625] m. Initialization-scale tests and a deterministic 12-geometry, two-level Plackett-Burman screen further characterize empirical local recovery and within-design geometric sensitivity. These synthetic results are limited to calibrated two-dimensional geometry, a finite-dimensional reflector, known single-bounce association, a nongrazing local branch, and branch-valid initialization; they do not establish global path uniqueness, convergence from arbitrary initial values, or vehicle-mounted experimental validity.

| [1] |
S. L. Lin, An edge-assisted Internet-of-Vehicles computing framework for fair tail-risk allocation in cooperative autonomous driving, Comput. Mater. Continua, 88 (2026), 11. https://doi.org/10.32604/cmc.2026.084571 doi: 10.32604/cmc.2026.084571

|
| [2] |
S. L. Lin, Nonlinear stability and critical penetration analysis of mixed autonomous traffic with anticipative optimal-velocity control, AIMS Math., 11 (2026), 15302-15323. https://doi.org/10.3934/math.2026629 doi: 10.3934/math.2026629
|
| [3] |
S. L. Lin, Y. H. Chen, Deep learning-aided frequency-modulated continuous-wave radar for around-the-corner non-line-of-sight perception at urban intersections, Comput. Model. Eng. Sci., 147 (2026), 37. https://doi.org/10.32604/cmes.2026.078862 doi: 10.32604/cmes.2026.078862
|
| [4] |
S. L. Lin, Advanced multi-channel echo separation techniques for high-interference automotive radars, Comput. Mater. Continua, 85 (2025), 1365-1382. https://doi.org/10.32604/cmc.2025.067764 doi: 10.32604/cmc.2025.067764
|
| [5] |
W. T. Hsu, S. L. Lin, Using FMCW in autonomous cars to accurately estimate the distance of the preceding vehicle, Int. J. Auto. Tech., 23 (2022), 1755-1762. https://doi.org/10.1007/s12239-022-0153-4 doi: 10.1007/s12239-022-0153-4
|
| [6] |
A. Sume, M. Gustafsson, M. Herberthson, A. Jänis, S. Nilsson, J. Rahm, Radar detection of moving targets behind corners, IEEE Trans. Geosci. Remote Sens., 49 (2011), 2259-2267. https://doi.org/10.1109/TGRS.2010.2096471 doi: 10.1109/TGRS.2010.2096471
|
| [7] |
P. Setlur, G. E. Smith, F. Ahmad, M. G. Amin, Target localization with a single sensor via multipath exploitation, IEEE Trans. Aerosp. Electron. Syst., 48 (2012), 1996-2014. https://doi.org/10.1109/TAES.2012.6237575 doi: 10.1109/TAES.2012.6237575
|
| [8] |
O. Rabaste, E. Colin-Koeniguer, D. Poullin, A. Cheraly, J. F. Pétex, H. K. Phan, Around-the-corner radar: detection of a human being in non-line of sight, IET Radar Sonar Nav., 9 (2015), 660-668. https://doi.org/10.1049/iet-rsn.2014.0337 doi: 10.1049/iet-rsn.2014.0337
|
| [9] |
R. Zetik, M. Eschrich, S. Jovanoska, R. S. Thomä, Looking behind a corner using multipath-exploiting UWB radar, IEEE Trans. Aerosp. Electron. Syst., 51 (2015), 1916-1926. https://doi.org/10.1109/TAES.2015.140303 doi: 10.1109/TAES.2015.140303
|
| [10] |
K. P. H. Thai, O. Rabaste, J. Bosse, D. Poullin, I. D. H. Sáenz, T. Letertre, Detection-localization algorithms in the around-the-corner radar problem, IEEE Trans. Aerosp. Electron. Syst., 55 (2019), 2658-2673. https://doi.org/10.1109/TAES.2019.2897031 doi: 10.1109/TAES.2019.2897031
|
| [11] |
X. Q. Yang, S. H. Fan, S. S. Guo, S. L. Li, G. L. Cui, W. Zhang, NLOS target localization behind an L-shaped corner with an L-band UWB radar, IEEE Access, 8 (2020), 31270-31286. https://doi.org/10.1109/ACCESS.2020.2973046 doi: 10.1109/ACCESS.2020.2973046
|
| [12] |
S. L. Li, S. S. Guo, J. H. Chen, X. Q. Yang, S. H. Fan, C. Jia, Multiple targets localization behind L-shaped corner via UWB radar, IEEE Trans. Veh. Technol., 70 (2021), 3087-3100. https://doi.org/10.1109/TVT.2021.3068266 doi: 10.1109/TVT.2021.3068266
|
| [13] |
Q. Tang, J. Li, L. Y. Wang, Y. Jia, G. L. Cui, Multipath imaging for NLOS targets behind an L-shaped corner with single-channel UWB radar, IEEE Sens. J., 22 (2022), 1531-1540. https://doi.org/10.1109/JSEN.2021.3131665 doi: 10.1109/JSEN.2021.3131665
|
| [14] |
J. H. Chen, S. S. Guo, H. L. Luo, N. Li, G. L. Cui, Non-line-of-sight multi-target localization algorithm for driver-assistance radar system, IEEE Trans. Veh. Technol., 72 (2023), 5332-5337. https://doi.org/10.1109/TVT.2022.3227971 doi: 10.1109/TVT.2022.3227971
|
| [15] |
Z. Y. Liu, W. L. Zhang, J. Y. Zheng, S. S. Guo, G. L. Cui, L. J. Kong, Non-LOS target localization via millimeter-wave automotive radar, J. Syst. Eng. Electron., 34 (2023), 1171-1181. https://doi.org/10.23919/JSEE.2023.000070 doi: 10.23919/JSEE.2023.000070
|
| [16] |
D. Kang, D. Kum, Camera and radar sensor fusion for robust vehicle localization via vehicle part localization, IEEE Access, 8 (2020), 75223-75236. https://doi.org/10.1109/ACCESS.2020.2985075 doi: 10.1109/ACCESS.2020.2985075
|
| [17] |
Y. D. Li, D. H. Zhang, R. X. Geng, Z. Lu, Z. Wu, Y. Hu, et al., A high-resolution handheld millimeter-wave imaging system with phase error estimation and compensation, Commun. Eng., 3 (2024), 4. https://doi.org/10.1038/s44172-023-00156-2 doi: 10.1038/s44172-023-00156-2
|
| [18] |
C. Gentner, T. Jost, W. Wang, S. W. Zhang, A. Dammann, U. C. Fiebig, Multipath assisted positioning with simultaneous localization and mapping, IEEE Trans. Wirel. Commun., 15 (2016), 6104-6117. https://doi.org/10.1109/TWC.2016.2578336 doi: 10.1109/TWC.2016.2578336
|
| [19] |
E. Leitinger, P. Meissner, C. Rüdisser, G. Dumphart, K. Witrisal, Evaluation of position-related information in multipath components for indoor positioning, IEEE J. Sel. Areas Commun., 33 (2015), 2313-2328. https://doi.org/10.1109/JSAC.2015.2430520 doi: 10.1109/JSAC.2015.2430520
|
| [20] |
E. Leitinger, A. Venus, B. Teague, F. Meyer, Data fusion for multipath-based SLAM: combining information from multiple propagation paths, IEEE Trans. Signal Process., 71 (2023), 4011-4028. https://doi.org/10.1109/TSP.2023.3310360 doi: 10.1109/TSP.2023.3310360
|
| [21] |
H. Godrich, A. M. Haimovich, R. S. Blum, Target localization accuracy gain in MIMO radar-based systems, IEEE Trans. Inform. Theory, 56 (2010), 2783-2803. https://doi.org/10.1109/TIT.2010.2046246 doi: 10.1109/TIT.2010.2046246
|
| [22] |
Y. Shen, M. Z. Win, Fundamental limits of wideband localization-Part I: A general framework, IEEE Trans. Inform. Theory, 56 (2010), 4956-4980. https://doi.org/10.1109/TIT.2010.2060110 doi: 10.1109/TIT.2010.2060110
|
| [23] |
M. O'Toole, D. B. Lindell, G. Wetzstein, Confocal non-line-of-sight imaging based on the light-cone transform, Nature, 555 (2018), 338-341. https://doi.org/10.1038/nature25489 doi: 10.1038/nature25489
|
| [24] |
K. Levenberg, A method for the solution of certain non-linear problems in least squares, Quart. Appl. Math., 2 (1944), 164-168. https://doi.org/10.1090/qam/10666 doi: 10.1090/qam/10666
|
| [25] |
D. W. Marquardt, An algorithm for least-squares estimation of nonlinear parameters, J. Soc. Indust. Appl. Math., 11 (1963), 431-441. https://doi.org/10.1137/0111030 doi: 10.1137/0111030
|
| [26] |
S. H. Son, K. J. Lee, W. K. Park, Real-time tracking of moving objects from scattering matrix in real-world microwave imaging, AIMS Math., 9 (2024), 13570-13588. https://doi.org/10.3934/math.2024662 doi: 10.3934/math.2024662
|
| [27] |
S. Kang, W. K. Park, A novel study on the bifocusing method for imaging unknown objects in two-dimensional inverse scattering problem, AIMS Math., 8 (2023), 27080-27112. https://doi.org/10.3934/math.20231386 doi: 10.3934/math.20231386
|
| [28] |
W. K. Park, On the identification of small anomaly in microwave imaging without homogeneous background information, AIMS Math., 8 (2023), 27210-27226. https://doi.org/10.3934/math.20231392 doi: 10.3934/math.20231392
|
| [29] |
J. Eom, W. K. Park, Real-time detection of small objects in transverse electric polarization: evaluations on synthetic and experimental datasets, AIMS Math., 9 (2024), 22665-22679. https://doi.org/10.3934/math.20241104 doi: 10.3934/math.20241104
|
| [30] |
B. W. Tang, X. Y. Yang, L. Su, Shape reconstruction of acoustic obstacle with linear sampling method and neural network, AIMS Math., 9 (2024), 13607-13623. https://doi.org/10.3934/math.2024664 doi: 10.3934/math.2024664
|
| [31] |
P. Wang, J. J. Huang, W. J. He, J. Q. Zhang, F. Guo, Maximum likelihood DOA estimation based on improved invasive weed optimization algorithm and application of MEMS vector hydrophone array, AIMS Math., 7 (2022), 12342-12363. https://doi.org/10.3934/math.2022685 doi: 10.3934/math.2022685
|
| [32] |
I. M. Nasir, H. Alshaya, S. Tehsin, W. Bouchelligua, Cross-view remote sensing and street-level data fusion for intelligent traffic congestion analysis, AIMS Math., 11 (2026), 1547-1589. https://doi.org/10.3934/math.2026065 doi: 10.3934/math.2026065
|
| [33] |
D. Y. Zhu, Y. T. Yang, M. Y. Cao, An accelerated adaptive two-step Levenberg-Marquardt method with the modified Metropolis criterion, AIMS Math., 9 (2024), 24610-24635. https://doi.org/10.3934/math.20241199 doi: 10.3934/math.20241199
|
| [34] |
L. Y. Zhao, J. Y. Tang, Convergence properties of a family of inexact Levenberg-Marquardt methods, AIMS Math., 8 (2023), 18649-18664. https://doi.org/10.3934/math.2023950 doi: 10.3934/math.2023950
|
| [35] |
E. Alruwaili, Recovery of a time-dependent reaction coefficient in a space-time fractional diffusion model via Nyström discretization, AIMS Math., 11 (2026), 13196-13215. https://doi.org/10.3934/math.2026544 doi: 10.3934/math.2026544
|
| [36] |
R. L. Plackett, J. P. Burman, The design of optimum multifactorial experiments, Biometrika, 33 (1946), 305-325. https://doi.org/10.1093/biomet/33.4.305 doi: 10.1093/biomet/33.4.305
|
| [37] |
D. L. Liu, Y. Wang, P. He, Y. Zhai, H. Y. Wang, TOA localization for multipath and NLOS environment with virtual stations, EURASIP J. Wirel. Commun. Netw., 2017 (2017), 104. https://doi.org/10.1186/s13638-017-0896-1 doi: 10.1186/s13638-017-0896-1
|
| [38] |
E. Wise, Q. L. Cheng, J. Kelly, Spatiotemporal calibration of 3-D millimetre-wavelength radar-camera pairs, IEEE Trans. Robot., 39 (2023), 4552-4566. https://doi.org/10.1109/TRO.2023.3311680 doi: 10.1109/TRO.2023.3311680
|
| [39] |
L. Zheng, J. M. Long, M. Lops, F. Liu, X. Y. Hu, C. H. Zhao, Detection of ghost targets for automotive radar in the presence of multipath, IEEE Trans. Signal Process., 72 (2024), 2204-2220. https://doi.org/10.1109/TSP.2024.3384750 doi: 10.1109/TSP.2024.3384750
|
Figures(8) / Tables(6)
Shih-Lin Lin. Curvature-aware inverse specular geometry for camera-assisted mmWave NLoS localization: identifiability, stability, and numerical analysis[J]. AIMS Mathematics, 2026, 11(10): 34661-34698. doi: 10.3934/math.20261351



 DownLoad: