Finite-time surrounding control possesses superior performance in terms of tracking accuracy and rapidity. Nevertheless, most existing finite-time surrounding algorithms are only applicable to integrator systems, restricted to single-target scenarios, and fail to maintain rapid dynamic responses throughout the entire convergence process. To address these limitations, this paper extends the framework to multiple moving targets and generalizes integrators to nonlinear systems with unknown control coefficients. Meanwhile, an accelerated distributed control scheme is developed to improve the convergence performance of each agent throughout the entire process. Specifically, dynamic high-gain distributed observers are constructed for each follower, which achieve target state estimation merely using local relative information. Combined with adaptive techniques, a novel accelerated distributed surrounding protocol based on high-gain is proposed, which realizes finite-time multi-target encirclement and significantly improves global convergence rapidity compared with existing finite-time strategies. The embedded dynamic high-gain mechanism effectively compensates the unknown control coefficients while strictly preserving the fully distributed feature of the protocol, which guarantees strong operational robustness. Numerical simulations further verify the feasibility and effectiveness of the developed control scheme, demonstrating its promising application potential in practical multi-agent cooperative surrounding missions.
Citation: Le Zhao. Accelerated finite-time surrounding control for multiple moving targets[J]. Electronic Research Archive, 2026, 34(12): 9138-9168. doi: 10.3934/era.2026385
Finite-time surrounding control possesses superior performance in terms of tracking accuracy and rapidity. Nevertheless, most existing finite-time surrounding algorithms are only applicable to integrator systems, restricted to single-target scenarios, and fail to maintain rapid dynamic responses throughout the entire convergence process. To address these limitations, this paper extends the framework to multiple moving targets and generalizes integrators to nonlinear systems with unknown control coefficients. Meanwhile, an accelerated distributed control scheme is developed to improve the convergence performance of each agent throughout the entire process. Specifically, dynamic high-gain distributed observers are constructed for each follower, which achieve target state estimation merely using local relative information. Combined with adaptive techniques, a novel accelerated distributed surrounding protocol based on high-gain is proposed, which realizes finite-time multi-target encirclement and significantly improves global convergence rapidity compared with existing finite-time strategies. The embedded dynamic high-gain mechanism effectively compensates the unknown control coefficients while strictly preserving the fully distributed feature of the protocol, which guarantees strong operational robustness. Numerical simulations further verify the feasibility and effectiveness of the developed control scheme, demonstrating its promising application potential in practical multi-agent cooperative surrounding missions.

| [1] |
J. Ghommam, M. Saad, F. Mnif, Finite-time circular formation around a moving target with multiple underactuated ODIN vehicles, Math. Comput. Simul., 180 (2021), 230–250. https://doi.org/10.1016/j.matcom.2020.08.026 doi: 10.1016/j.matcom.2020.08.026
|
| [2] |
D. Ma, S. C. Sun, Finite-time circle surrounding control for multi-agent systems, Int. J. Control Autom. Syst., 15 (2017), 1536–1543. https://doi.org/10.1007/s12555-016-0055-1 doi: 10.1007/s12555-016-0055-1
|
| [3] |
L. P. Mo, Y. G. Yu, Finite-time rotating encirclement control of multi-agent systems, Acta Autom. Sin., 43 (2017), 1665–1672. https://doi.org/10.16383/j.aas.2017.e160260 doi: 10.16383/j.aas.2017.e160260
|
| [4] |
K. L. Huang, C. D. Liang, M. F. Ge, X. Liu, Q. Chen, W. Cai, Finite-time multi-surrounding control of networked marine surface vehicles: A three-layer-hierarchical approach, Ocean Eng., 294 (2024), 116702. https://doi.org/10.1016/j.oceaneng.2024.116702 doi: 10.1016/j.oceaneng.2024.116702
|
| [5] |
A. Sharghi, M. Baradarannia, F. Hashemzadeh, Finite-time-estimation-based surrounding control for a class of unknown nonlinear multi-agent systems, Nonlinear Dyn., 96 (2019), 1795–1804. https://doi.org/10.1007/s11071-019-04884-z doi: 10.1007/s11071-019-04884-z
|
| [6] |
C. Li, H. Y. Wu, C. Yang, Q. Liu, J. Cao, T. Yu, Finite-time consensus for nonlinear uncertain PDE multi-agent systems with time-varying delays via boundary control, Inf. Sci., 754 (2026), 123736. https://doi.org/10.1016/j.ins.2026.123736 doi: 10.1016/j.ins.2026.123736
|
| [7] |
J. H. Wang, C. Wang, C. P. Chen, Z. Liu, C. L. Zhang, Fast finite-time event-triggered consensus control for uncertain nonlinear multiagent systems with full-state constraints, IEEE Trans. Circuits Syst. I Regul. Pap., 70 (2023), 1361–1370. https://doi.org/10.1109/TCSI.2022.3225287 doi: 10.1109/TCSI.2022.3225287
|
| [8] |
Z. Y. Gao, J. Zhang, H. G. Su, Z. Q. Yang, Distributed bipartite containment for heterogeneous fractional-order multiagent systems with finite-time and event-triggered control strategies, Asian J. Control, 28 (2026), 2068–2079. https://doi.org/10.1002/asjc.3815 doi: 10.1002/asjc.3815
|
| [9] |
L. B. Wang, X. P. Liu, H. Q. Wang, Fast finite-time control for nonaffine stochastic nonlinear systems against multiple actuator constraints via output feedback, IEEE Trans. Cybern., 53 (2023), 3253–3262. https://doi.org/10.1109/TCYB.2022.3177587 doi: 10.1109/TCYB.2022.3177587
|
| [10] |
B. D. Ning, Q. L. Han, Z. Y. Zuo, L. Ding, Accelerated secondary frequency regulation and active power sharing for islanded microgrids with external disturbances: A fully distributed approach, Automatica, 174 (2025), 112146. https://doi.org/10.1016/j.automatica.2025.112146 doi: 10.1016/j.automatica.2025.112146
|
| [11] |
J. Zhao, H. Zhao, Y. Song, Z. Y. Sun, D. Yu, Fast finite-time consensus protocol for high-order nonlinear multi-agent systems based on event-triggered communication scheme, Appl. Math. Comput., 508 (2026), 129631. https://doi.org/10.1016/j.amc.2025.129631 doi: 10.1016/j.amc.2025.129631
|
| [12] |
H. Y. Zhang, Y. M. Li, K. W. Li, Event-triggered based adaptive finite-time enclosed control for multirobot systems via bearing information, Int. J. Robust Nonlinear Control, 36 (2026), 5291–5305. https://doi.org/10.1002/rnc.70513 doi: 10.1002/rnc.70513
|
| [13] |
L. F. Zhou, Y. N. Guo, Y. Zhang, P. X. Huang, P. Y. Wang, Noncooperative target finite-time surrounding control of spacecraft formation, Space Sci. Technol., 4 (2024), 0156. https://doi.org/10.34133/space.0156 doi: 10.34133/space.0156
|
| [14] |
Y. X. Cui, J. Luo, K. Cao, Y. Chen, J. Wang, Finite-time surrounding control of agents based on velocity field, in 2020 39th Chinese Control Conference, (2020), 4795–4800. https://doi.org/10.23919/CCC50068.2020.9188732 |
| [15] |
B. B. Hu, H. T. Zhang, J. Wang, Multiple-target surrounding and collision avoidance with second-order nonlinear multiagent systems, IEEE Trans. Ind. Electron., 68 (2021), 7454–7463. https://doi.org/10.1109/TIE.2020.3000092 doi: 10.1109/TIE.2020.3000092
|
| [16] |
F. Chen, W. Ren, Y. C. Cao, Surrounding control in cooperative agent networks, Syst. Control Lett., 59 (2010), 704–712. https://doi.org/10.1016/j.sysconle.2010.08.006 doi: 10.1016/j.sysconle.2010.08.006
|
| [17] |
S. Shoja, M. Baradarannia, F. Hashemzadeh, M. Badamchizadeh, P. Bagheri, Surrounding control of nonlinear multi-agent systems with non-identical agents, ISA Trans., 70 (2017), 219–227. https://doi.org/10.1016/j.isatra.2017.06.011 doi: 10.1016/j.isatra.2017.06.011
|
| [18] |
T. F. Zhang, J. H. Ling, L. P. Mo, Distributed finite-time rotating encirclement control of multiagent systems with nonconvex input constraints, IEEE Access, 7 (2019), 102477–102486. https://doi.org/10.1109/ACCESS.2019.2930869 doi: 10.1109/ACCESS.2019.2930869
|
| [19] |
L. Zhang, Finite-time enclosing control for multiple moving targets: A continuous estimator approach, preprint, arXiv: 2202.00347. https://doi.org/10.48550/arXiv.2202.00347 |
| [20] |
M. F. Ge, J. W. Dong, Z. W. Liu, Hierarchical fuzzy fault-tolerant controller synthesis for finite-time multi-target surrounding of networked perturbed mechanical systems, IEEE Trans. Fuzzy Syst., 31 (2023), 760–773. https://doi.org/10.1109/TFUZZ.2022.3189393 doi: 10.1109/TFUZZ.2022.3189393
|
| [21] |
L. W. Kou, Z. Y. Chen, J. Xiang, Cooperative fencing control of multiple vehicles for a moving target with an unknown velocity, IEEE Trans. Autom. Control, 67 (2022), 1008–1015. https://doi.org/10.1109/TAC.2021.3075320 doi: 10.1109/TAC.2021.3075320
|
| [22] |
Z. J. Ma, T. Kirubarajan, Y. Y. Li, Finite-time encirclement rotating tracking for surface formation targets with bearing-only measurements, Nonlinear Dyn., 105 (2021), 3323–3339. https://doi.org/10.1007/s11071-021-06818-0 doi: 10.1007/s11071-021-06818-0
|
| [23] |
Z. Y. Chen, A cooperative target-fencing protocol of multiple vehicles, Automatica, 107 (2019), 591–594. https://doi.org/10.1016/j.automatica.2019.05.034 doi: 10.1016/j.automatica.2019.05.034
|
| [24] |
S. Ju, J. Wang, L. Y. Dou, Enclosing control for multiagent systems with a moving target of unknown bounded velocity, IEEE Trans. Cybern., 52 (2022), 11561–11570. https://doi.org/10.1109/TCYB.2021.3072031 doi: 10.1109/TCYB.2021.3072031
|
| [25] |
Y. Kobayashi, K. Otsubo, S. Hosoe, Design of decentralized capturing behavior by multiple mobile robots, in IEEE Workshop on Distributed Intelligent Systems: Collective Intelligence and Its Applications, (2006), 13–18. https://doi.org/10.1109/DIS.2006.23 |
| [26] |
S. Hara, T. H. Kim, Y. Hori, Distributed formation control for target-enclosing operations based on a cyclic pursuit strategy, in 17th IFAC World Congress, (2008), 6602–6607. https://doi.org/10.3182/20080706-5-KR-1001.01113 |
| [27] |
S. Y. Khoo, L. H. Xie, S. K. Zhao, Z. H. Man, Multi-surface sliding control for fast finite-time leader-follower consensus with high order SISO uncertain nonlinear agents, Int. J. Robust Nonlinear Control, 24 (2014), 2388–2404. https://doi.org/10.1002/rnc.2997 doi: 10.1002/rnc.2997
|
| [28] |
G. Hardy, J. Littlewood, G. Polya, Inequalities, Cambridge University Press, (1952), 751–766. |
| [29] |
F. Wang, Z. You, Z. Liu, C. P. Chen, A fast finite-time neural network control of stochastic nonlinear systems, IEEE Trans. Neural Netw. Learn. Syst., 34 (2022), 7443–7452. https://doi.org/10.1109/TNNLS.2022.3143655 doi: 10.1109/TNNLS.2022.3143655
|
| [30] |
C. Sun, G. Q. Hu, L. H. Xie, M. Egerstedt, Robust finite-time connectivity preserving coordination of second-order multi-agent systems, Automatica, 89 (2018), 21–27. https://doi.org/10.1016/j.automatica.2017.11.020 doi: 10.1016/j.automatica.2017.11.020
|
| [31] |
J. S. Huang, C. Y. Wen, W. Wang, Y. D. Song, Adaptive finite-time consensus control of a group of uncertain nonlinear mechanical systems, Automatica, 51 (2015), 292–301. https://doi.org/10.1016/j.automatica.2014.10.093 doi: 10.1016/j.automatica.2014.10.093
|
| [32] |
A. F. Filippov, Differential equations with discontinuous righthand sides: Control systems, Springer Science & Business Media, 1988 |
| [33] |
J. X. Xu, Adaptive fixed-time control for MIMO nonlinear systems with asymmetric output constraints using universal barrier functions, IEEE Trans. Autom. Control, 64 (2019), 3046–3053. https://doi.org/10.1109/TAC.2018.2874877 doi: 10.1109/TAC.2018.2874877
|
Figures(12)
Le Zhao. Accelerated finite-time surrounding control for multiple moving targets[J]. Electronic Research Archive, 2026, 34(12): 9138-9168. doi: 10.3934/era.2026385

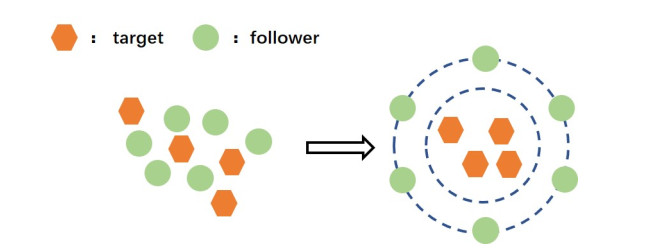
Six followers surrounding four moving targets
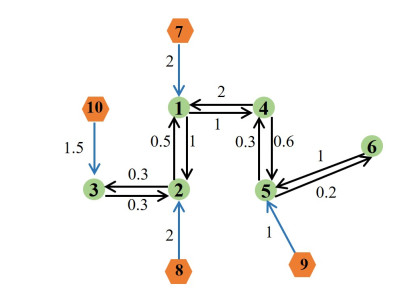
Graph with six followers and four targets
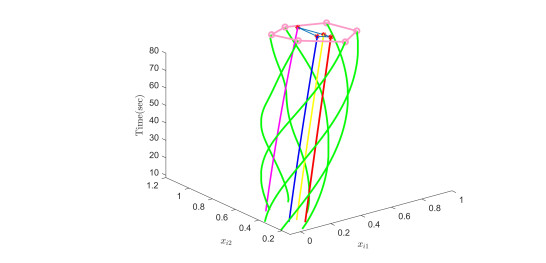
Encirclement configuration with six followers encircling four moving targets
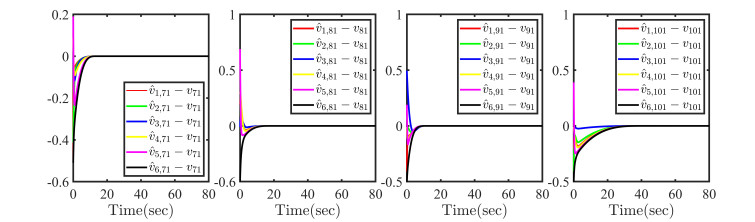
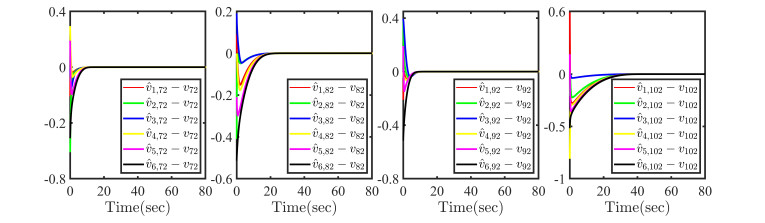
The trajectories of observer errors $ {{\hat{v}}_{ik1}}-{{v}_{k1}} $, $ i = 1, \cdots, 6, k = 7, \cdots, 10 $
The trajectories of observer errors $ {{\hat{v}}_{ik2}}-{{v}_{k2}} $, $ i = 1, \cdots, 6, k = 7, \cdots, 10 $
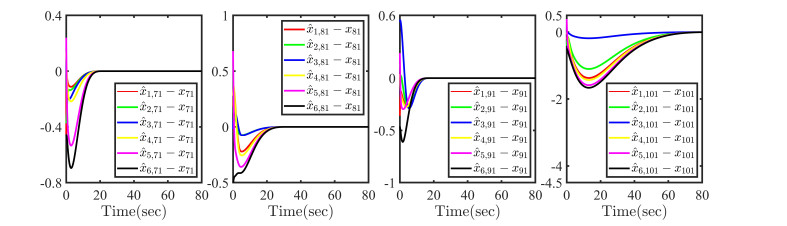
The trajectories of observer errors $ {{\hat{x}}_{ik1}}-{{x}_{k1}} $, $ i = 1, \cdots, 6, k = 7, \cdots, 10 $
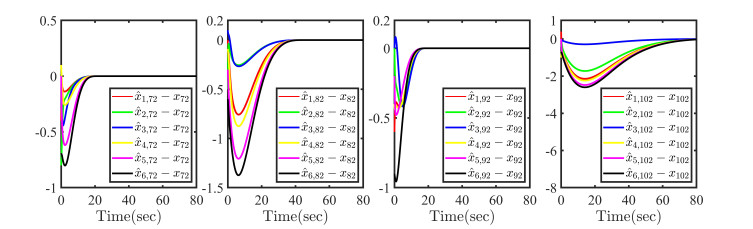
The trajectories of observer errors $ {{\hat{x}}_{ik2}}-{{x}_{k2}} $, $ i = 1, \cdots, 6, k = 7, \cdots, 10 $
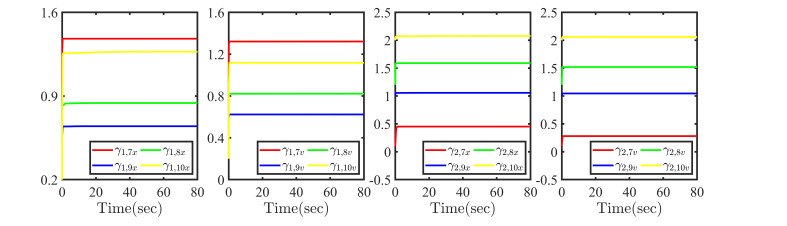
The trajectories of high gains $ {{\gamma }_{ikx}}, {{\gamma }_{ikv}} $, $ i = 1, 2, k = 7, \cdots, 10 $
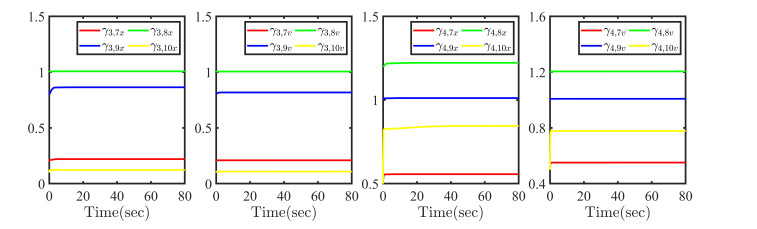
The trajectories of high gains $ {{\gamma }_{ikx}}, {{\gamma }_{ikv}} $, $ i = 3, 4, k = 7, \cdots, 10 $
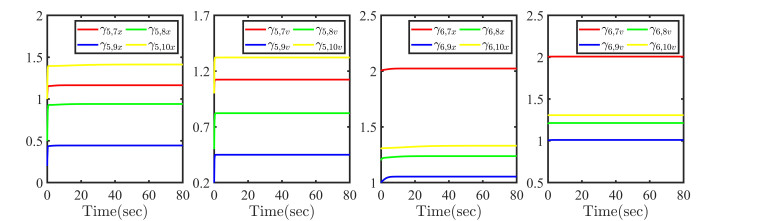
The trajectories of high gains $ {{\gamma }_{ikx}}, {{\gamma }_{ikv}} $, $ i = 5, 6, k = 7, \cdots, 10 $
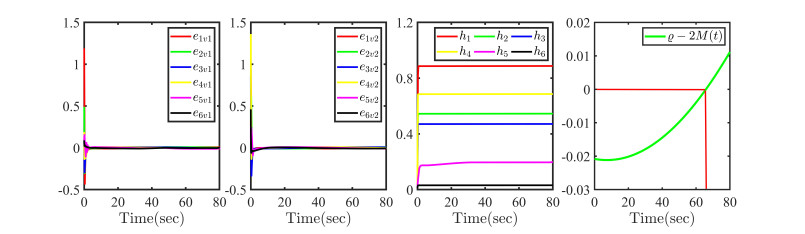
The trajectories of errors $ {{e}_{ivs}} $, high gains $ {{h}_{i}} $, and $ \varrho-2M(t) $, $ i = 1, \cdots, 6, s = 1, 2 $
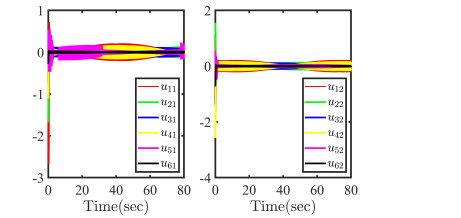
The trajectories of controls $ {{u}_{is}} $, $ i = 1, \cdots, 6, s = 1, 2$


 DownLoad: